INDEPENDENT ROBOTICS ENGINEERING / 2026

Intelligence
in motion.

Engineering autonomous systems from the ground up — where perception, learning, control, and real hardware meet.

01 / PERCEPTION 02 / CONTROL 03 / LEARNING
ACUS / SYSTEM CONCEPT RESEARCH
Conceptual diagram of an intelligent mobile manipulator RGB-D / INPUT 6-DoF / ARM MOBILE BASE FIG. 001 PERCEPTION → ACTION
FIG 01 — AUTONOMOUS SYSTEMS STUDYR&D / 001
SCROLL TO EXPLOREAPPLIED ROBOTICS / R&D 2026
01 / THE FOCUS

Robotics is a systems problem. We work across the stack.

From embedded electronics and mechanical integration to vision, planning, and machine learning, our work explores how complete robotic systems can operate reliably beyond a simulation.

PERCEPTIONPLANNINGCONTROLDEPLOYMENT
02 / SELECTED WORK

Systems under development.

Applied projects across manipulation, mobility, and autonomy.

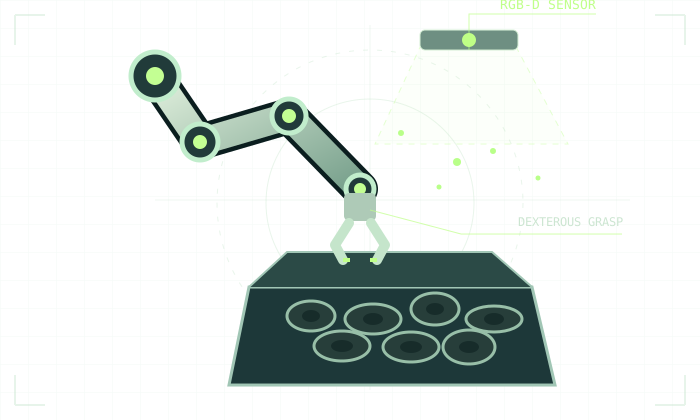
R&D / 01Concept illustration of a robotic arm selecting an object using RGB-D sensingPERCEPTION-TO-GRASP
DEXTEROUS MANIPULATIONArchitecture development

Vision-guided robotic picking & inspection

An industrial automation concept built around a single overhead RGB-D sensor, a 6-DoF manipulator, and a dexterous hand. The planned pipeline investigates grasp candidate generation, motion planning, and residual reinforcement learning for near-contact refinement.

RGB-DMoveIt 2DiffusionResidual RL
Discuss this work
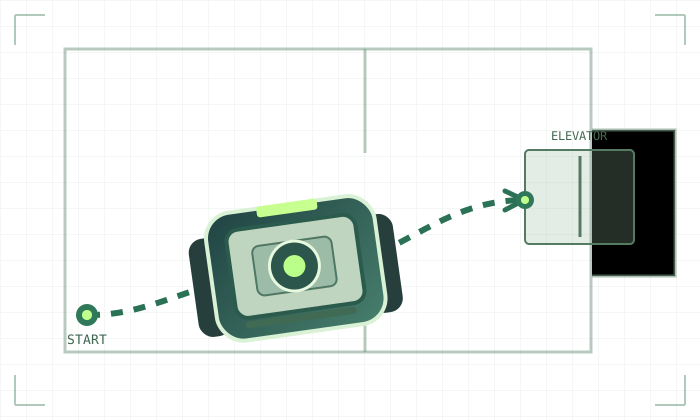
R&D / 02Technical drawing of an autonomous mobile robot and its navigation routeMOBILE AUTONOMY
AUTONOMOUS MOBILE ROBOTPrototype in progress

AMR for connected, multi-floor environments

A mobile robotics project spanning hardware integration, suspension design, power electronics, navigation, and elevator-aware operation. The system brings together embedded components and ROS 2-based autonomy.

ROS 2Nav2EmbeddedMechatronics
Discuss this work
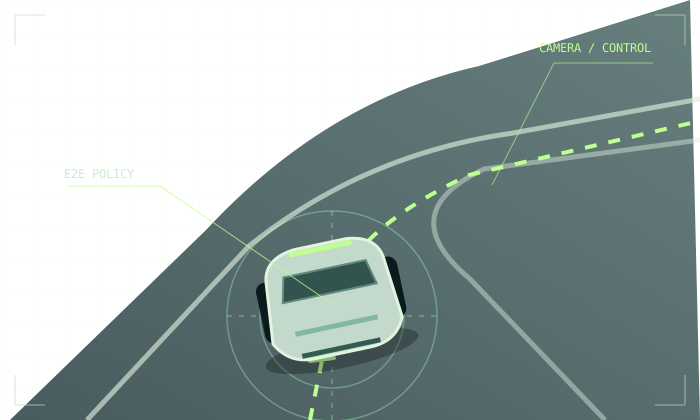
R&D / 03Technical illustration of autonomous driving with camera perception and lane geometryLEARNING-BASED CONTROL
AUTONOMOUS DRIVINGSimulation evaluated

End-to-end driving with multi-scale visual features

Research prototypes evaluated in CARLA, using camera inputs for steering and longitudinal control. The study explores behavior cloning, multi-scale visual representations, and reinforcement-learning-based policy refinement.

CARLAYOLOBehavior CloningPPO
Discuss this work
03 / EXPERTISE

An integrated engineering toolkit.

Methods and technologies used across our projects.

01 ↗

Perception

Computer vision, RGB-D sensing, object understanding, and visual representations.

RGB-D / VISION / 3D
02 ↗

Planning & control

Robot motion planning, trajectory tracking, kinematics, and closed-loop control.

MOVEIT 2 / NAV2 / IK
03 ↗

Robot learning

Imitation learning, reinforcement learning, and simulation-to-reality workflows.

BC / PPO / RESIDUAL RL
04 ↗

Systems integration

Embedded systems, motor control, electronics, and robotic hardware integration.

ROS 2 / EMBEDDED / HW
04 / DIRECTION

From promising ideas
to robots that work.

Our development direction is to connect learning-based intelligence with dependable physical robot systems — especially where perception, manipulation, and control must work together under real-world constraints.

SENSEREASONACT

Research and prototypes shown on this site are at different stages of development. Technical details and demonstrations can be shared on request.

05 / LET'S CONNECT

Let's build what comes next.

Interested in robotics research, engineering collaborations, or learning more about the projects? Get in touch.

CONTACT EMAIL[email protected]